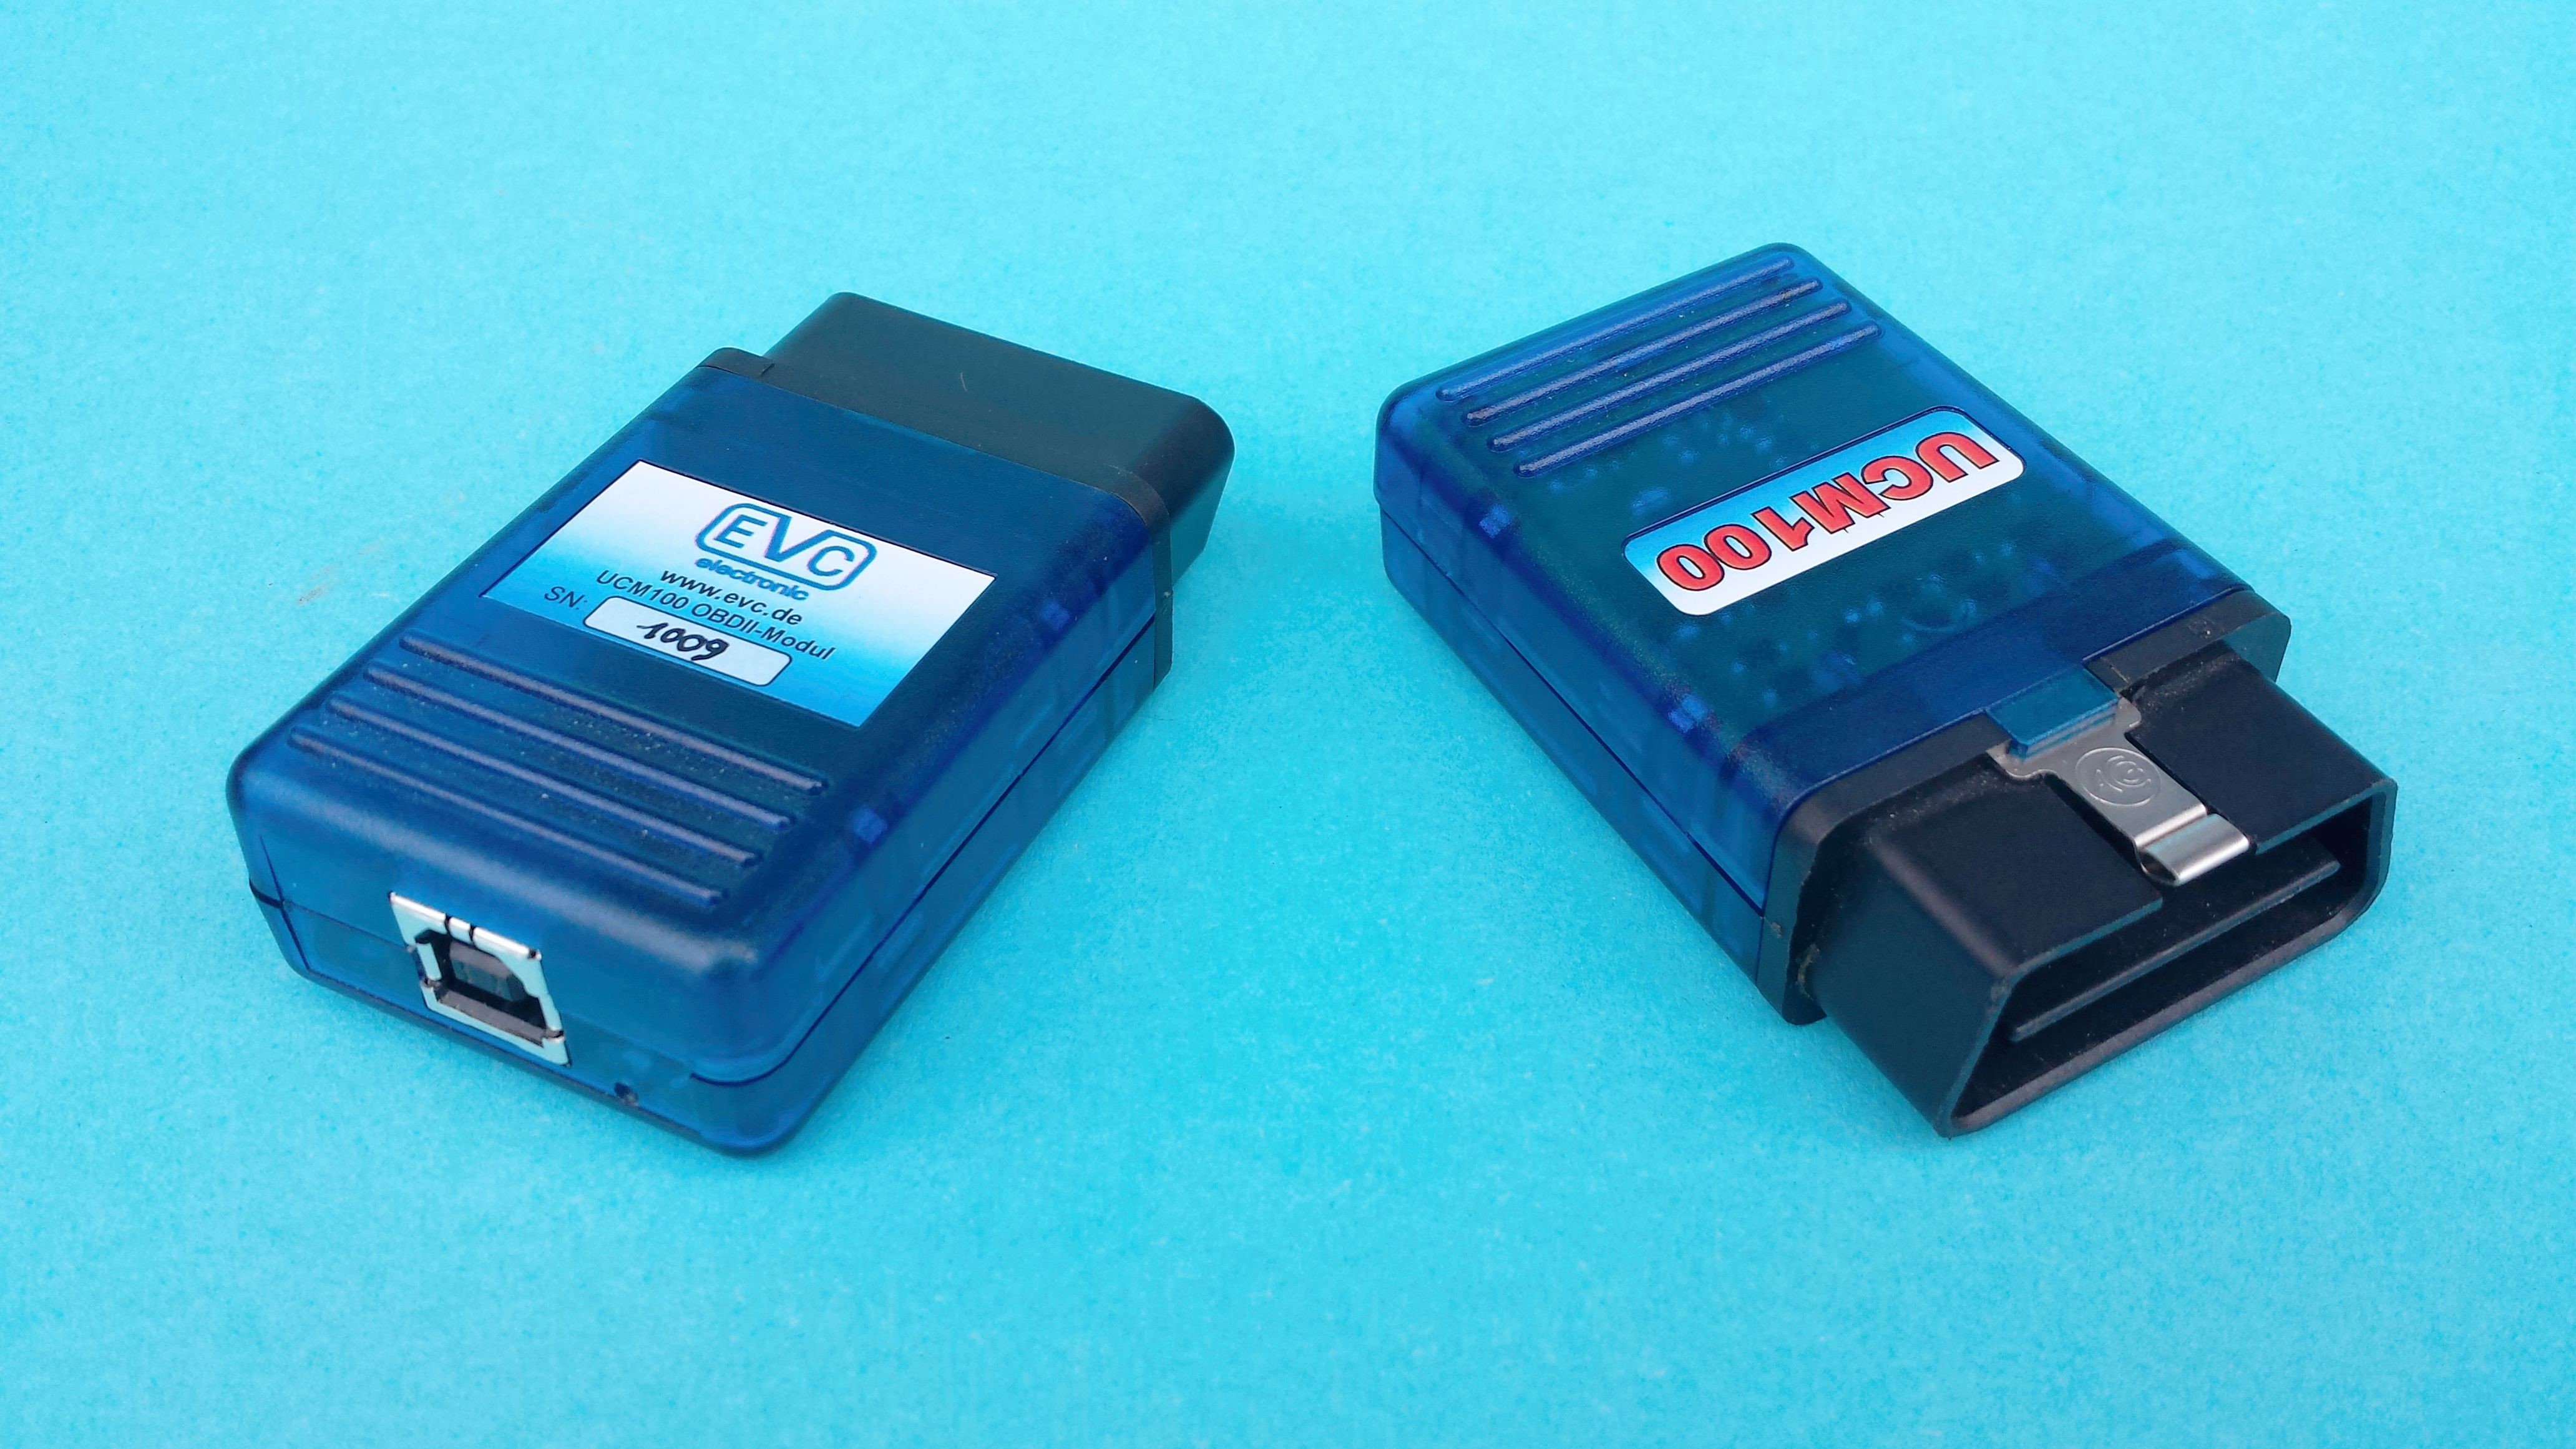
UCM100 is EVC’s OBD-II interface for standard diagnostic data, not a programmer. EVC says it reads SAE J1979 services over K-line or CAN: current data, stored and current faults, clearing the fault memory, and vehicle information such as the calibration verification number. The Windows program is WinUCM.
Selected live values can be saved to a log. WinOLS can open that log, or read the UCM100 directly, and show the values as a moving crosshair on a map. EVC’s access-indicator table says this shows measured values rather than the processor’s accesses to a map. Assigning those values to map axes is a manual PID assignment. The interface can be used at the vehicle without WinOLS running.
Sources
EVC: UCM100EVC: access indicator
Rendered revisions
Open each version to inspect formatting, tables and photographs.
UCM100 is EVC’s OBD-II interface for standard diagnostic data, not a programmer. EVC says it reads SAE J1979 services over K-line or CAN: current data, stored and current faults, clearing the fault memory, and vehicle information such as the calibration verification number. The Windows program is WinUCM.
Selected live values can be saved to a log. WinOLS can open that log, or read the UCM100 directly, and show the values as a moving crosshair on a map. EVC’s access-indicator table says this shows measured values rather than the processor’s accesses to a map. Assigning those values to map axes is a manual PID assignment. The interface can be used at the vehicle without WinOLS running.
UCM100 is EVC’s OBD-II interface for standard diagnostic data, not a programmer. EVC says it reads SAE J1979 services over K-line or CAN: current data, stored and current faults, clearing the fault memory, and vehicle information such as the calibration verification number. The Windows program is WinUCM.
Selected live values can be saved to a log. WinOLS can open that log, or read the UCM100 directly, and show the values as a moving crosshair on a map. EVC’s access-indicator table says this shows measured values rather than the processor’s accesses to a map. Assigning those values to map axes is a manual PID assignment. The interface can be used at the vehicle without WinOLS running.